


Car Racing
This environment is part of the Box2D environments which contains general information about the environment.
Action Space |
|
Observation Space |
|
Max Episode Steps |
|
Reward Threshold |
|
import |
|
Description
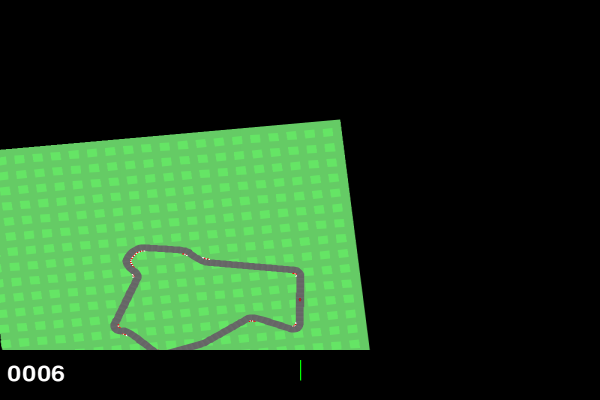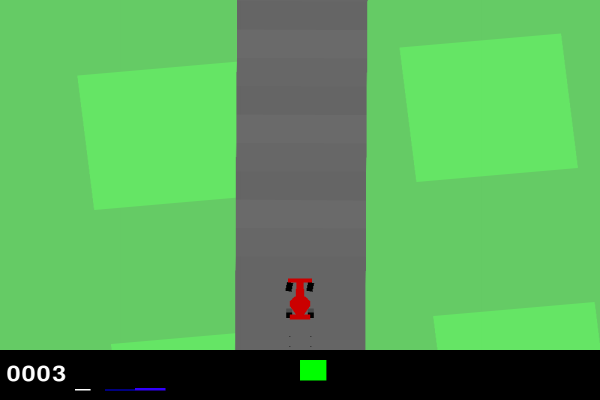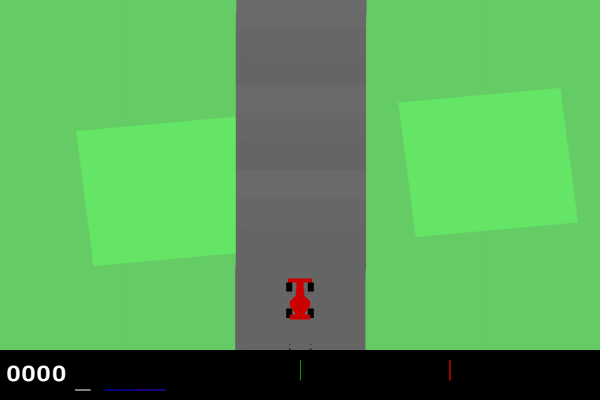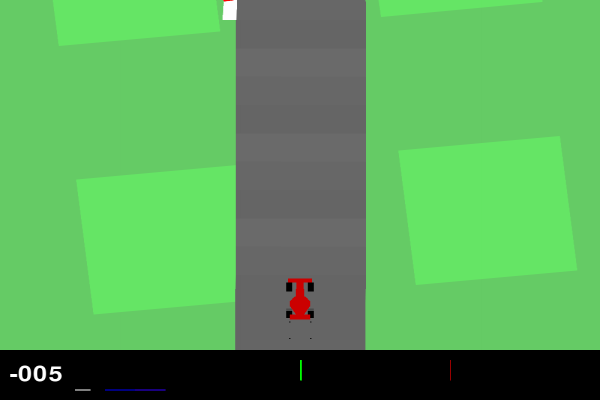
The easiest control task to learn from pixels - a top-down racing environment. The generated track is random every episode.
Some indicators are shown at the bottom of the window along with the state RGB buffer. From left to right: true speed, four ABS sensors, steering wheel position, and gyroscope. To play yourself (it’s rather fast for humans), type:
python gymnasium/envs/box2d/car_racing.py
Remember: it’s a powerful rear-wheel drive car - don’t press the accelerator and turn at the same time.
Action Space
If continuous (the default), the action is a Box([-1, 0, 0], [1, 1, 1], (3,), float32):
0: steering, -1 is full left, +1 is full right
1: gas, in
[0, 1]2: braking, in
[0, 1]
If discrete, the action space is Discrete(5):
0: do nothing
1: steer right
2: steer left
3: gas
4: brake
Observation Space
A top-down 96x96 RGB image of the car and race track, as a Box(0, 255, (96, 96, 3), uint8).
Rewards
The reward is -0.1 every frame and +1000/N for the first visit to each track tile, where N is the total number of tiles in the track. For example, if you have finished in 732 frames, your reward is 1000 - 0.1*732 = 926.8 points.
Starting State
The car starts at rest in the center of the road.
Episode End
The episode terminates when all the tiles are visited, with info["lap_finished"] = True.
The car can also go outside the playfield - that is, far off the track, in which case the reward for that
step is -100 and the episode terminates with info["lap_finished"] = False.
The episode is truncated after 1000 steps (the max_episode_steps of CarRacing-v3).
Information
step() returns an empty info dict, except on termination when it contains lap_finished (see above).
reset() returns an empty info dict.
Arguments
>>> import gymnasium as gym
>>> env = gym.make("CarRacing-v3", render_mode="rgb_array", lap_complete_percent=0.95, domain_randomize=False, continuous=False)
>>> env
<TimeLimit<OrderEnforcing<PassiveEnvChecker<CarRacing<CarRacing-v3>>>>>
lap_complete_percent=0.95is intended to dictate the fraction of tiles that must be visited by the agent before a lap is considered complete, checked when the car first visits the start tile. However, the start tile is already visited when the episode starts, so this check does not currently trigger and a lap is only complete once every tile has been visited.domain_randomize=Falseenables the domain randomized variant of the environment. In this scenario, the background and track colours are different on every reset.continuous=Truespecifies if the agent has continuous (true) or discrete (false) actions. See action space section for a description of each.verbose=Falseprints track generation information on reset ifTrue.render_modesupports"human","rgb_array"(a 600x400 image) and"state_pixels"(a 96x96 image, the same as the observation).
Reset Arguments
Passing the option options["randomize"] = True will change the current colour of the environment on demand.
Correspondingly, passing the option options["randomize"] = False will not change the current colour of the environment.
domain_randomize must be True on init for this argument to work.
>>> import gymnasium as gym
>>> env = gym.make("CarRacing-v3", domain_randomize=True)

# normal reset, this changes the colour scheme by default
>>> obs, _ = env.reset()

# reset with colour scheme change
>>> randomize_obs, _ = env.reset(options={"randomize": True})

# reset with no colour scheme change
>>> non_random_obs, _ = env.reset(options={"randomize": False})
Version History
v3: Change truncation to termination when finishing the lap (1.0.0)
v2: Remove
CarRacingDiscrete-v1, usecontinuous=Falseinstead (0.26.0)v1: Change track completion logic and add domain randomization (0.24.0)
v0: Original version
References
Chris Campbell (2014), http://www.iforce2d.net/b2dtut/top-down-car.
Credits
Created by Oleg Klimov